Loading...
Searching...
No Matches
test_object_simulator_clients.PoseRecorder Class Reference
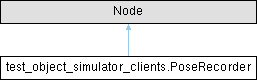
Inheritance diagram for test_object_simulator_clients.PoseRecorder:
Public Member Functions | |
| __init__ (self, prefix) | |
Public Attributes | |
| list | received = [] |
| pub = self.create_publisher(PoseStamped, f"{prefix}/get/pose", 1) | |
Protected Member Functions | |
| _cb (self, msg) | |
Protected Attributes | |
| _cb | |
Detailed Description
rclpy counterpart that records poses received on <prefix>/set/pose.
The documentation for this class was generated from the following file:
- src/sas_common/test/test_object_simulator_clients.py
